
Robotic Laboratory
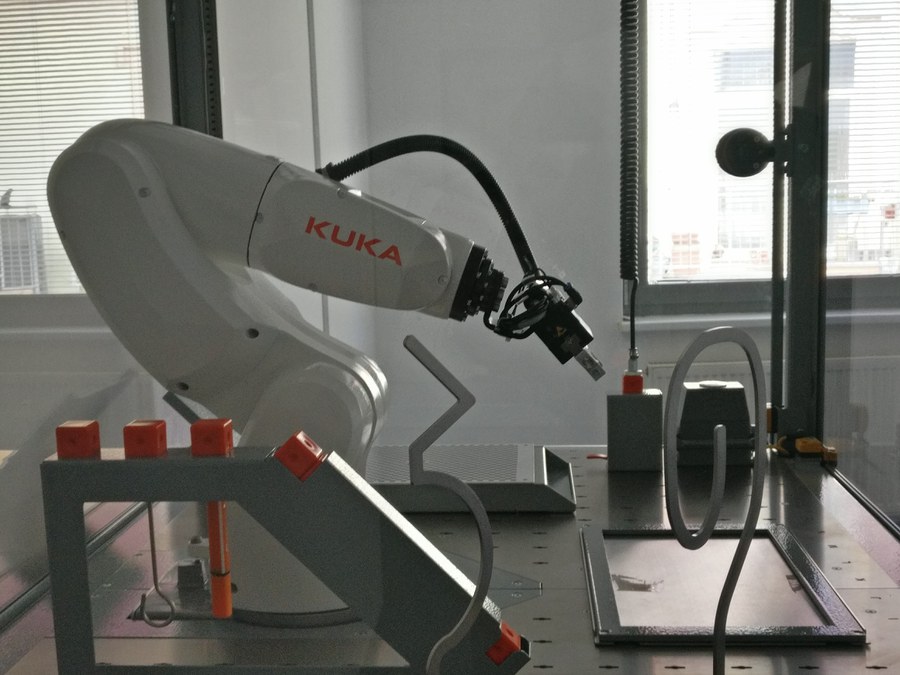
KUKA ready2_educate
The robot cell is equipped with a KUKA KR3 Agilus and the compact controller KR C4. The arm can lift up to 3 kilograms and has a reach of 60 cm. The robot cell also has the vision package for 2D image recognition and a vacuum gripper.
The robot is used in various research projects and in the BIW4-33 module.
Mobile Platform (Cooperation with University of Rostock)
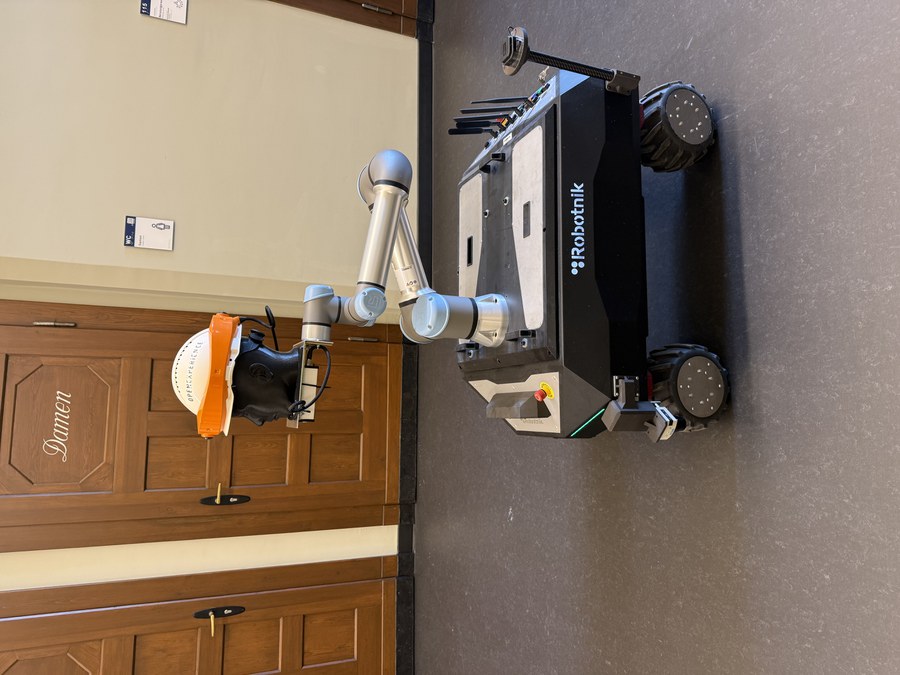
To investigate autonomous processes directly in the field and within dynamic environments, we utilize a mobile manipulation platform transferred from the University of Rostock:
-
Robotnik All-Terrain UGV: All-wheel-drive, rugged platform designed for rough terrain and construction site scenarios.
-
Universal Robots (UR) Robotic Arm: Multi-axis collaborative robot arm for flexible manipulation and positioning tasks.
-
Sensors & End-Effector: Integrated test setup (including cameras/sensors and a test head with OpenExperience safety equipment) for site measurement technology and human-robot interaction.
-
Communication: Multi-antenna system for wireless real-time data transmission and telemetry.